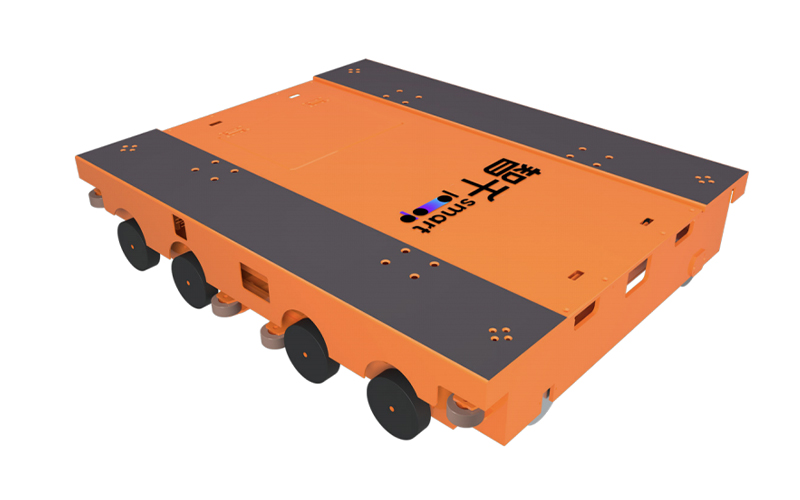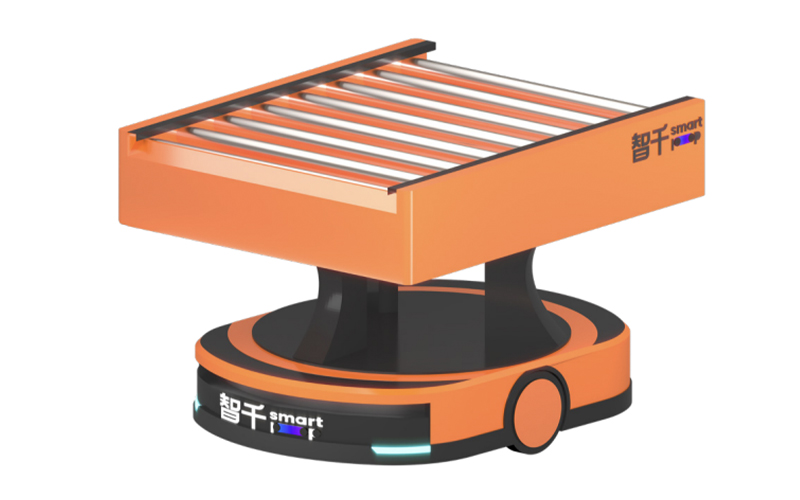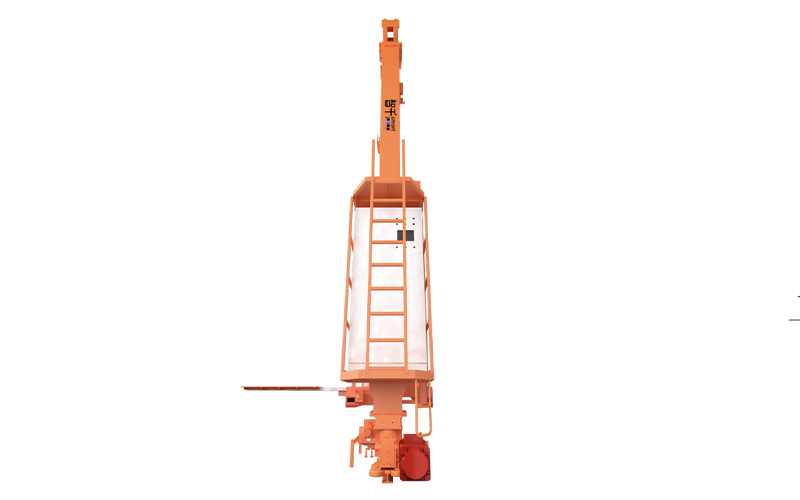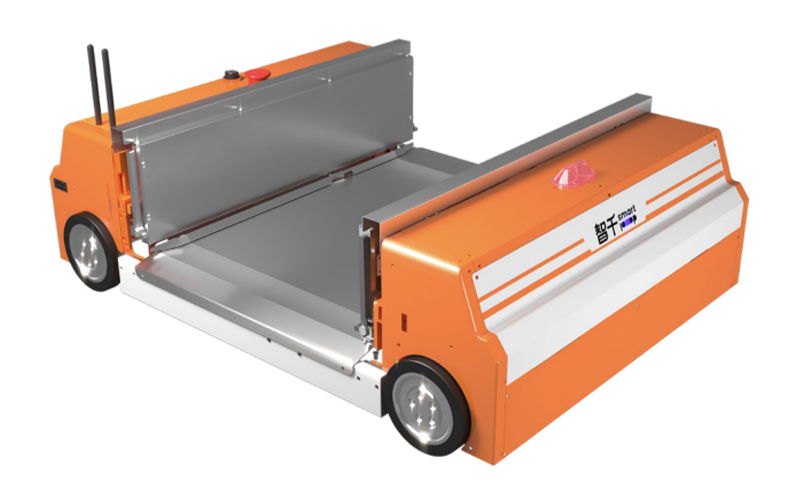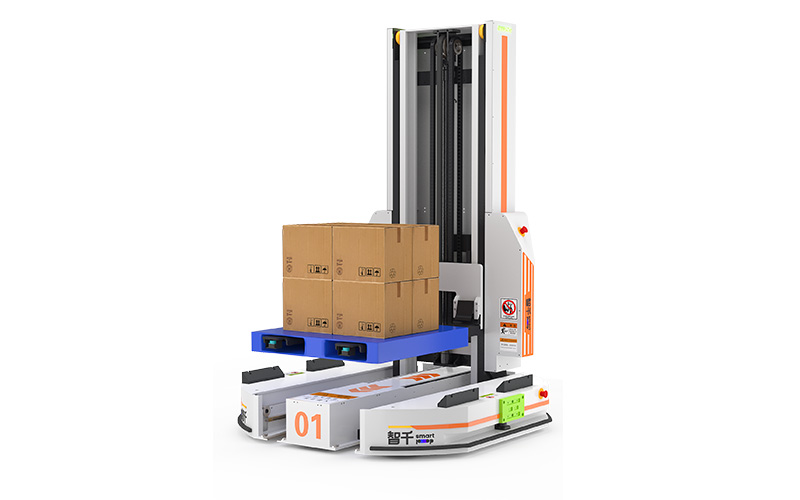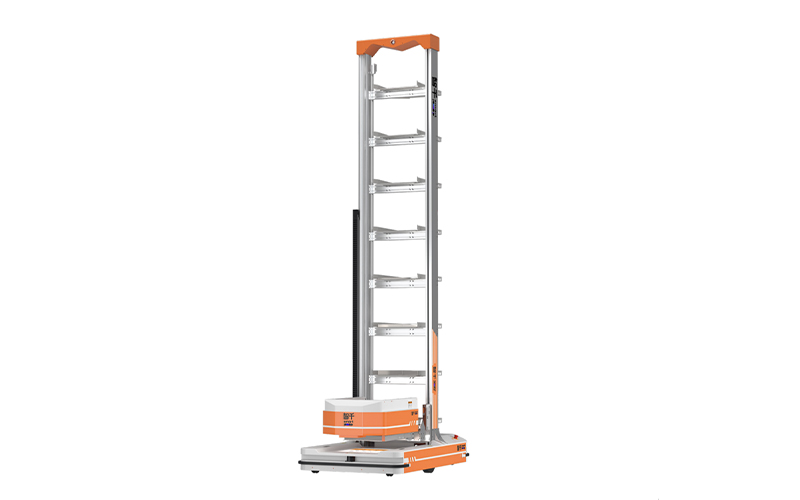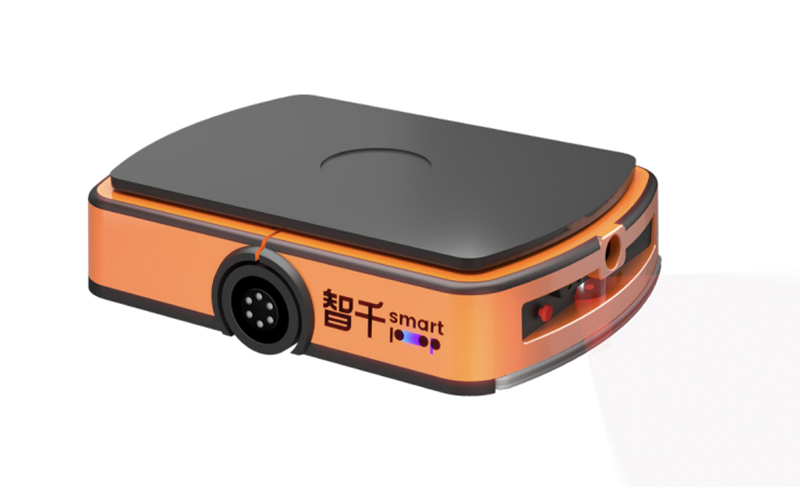

Relying on the autonomous navigation mode, the latent robot series integrates powerful functions such as compactness, flexibility, high precision, fast speed, autonomous route planning, and 360° rotation. Equipped with a rotary jacking system, the latent robot series can lift the shelf where the goods are located from the warehouse The storage area is transported to the designated place, which greatly improves the processing efficiency
Scenes to be used
It is used in 3C, express delivery, e-commerce, automobile, manufacturing, medicine, tobacco, food and beverage and otherindustries, and is used in the production and logistics links of various enterprises including shelf handling, raw material/semi-finishedproduct handling, parts sending and receiving, material transfer, etc.
Features
Dynamic resource allocation: Large-scale dynamic resource allocation can be realized, and the accuracy rate of artificial intelligencemass order optimization can be 99.99%: manual intervention is reduced throughout the process, and the system automaticallyguides operations;
Laser navigation precise positioning, light button to indicate the product;
Optimized management: Reasonable layout for hot and slow-moving switching, system function modularization, order systemoptimization, and inventory structure optimization;
Flexible and flexible: seamlessly connect OMS/MS and other upper-level software system projects with a short implementationperiod
Fast payback: 2-3 years payback period;
Automation: reduce labor by 60%-80%. The traditional picking method is inefficient and difficult to control labor costs. Orders arescattered, multi-item, and small in quantity. Almost all of them are dismantled and picked. The efficiency and accuracy of orderexecution directly affect the user experience;
|
model
|
 |
 |
 |
 |
 |
 |
 |
 |
|
|
ZQ8101
|
ZQ8102
|
ZQ8103 | ZQ8104 | ZQ8105 | ZQ8106 | ZQ8107 | ZQ8108 | ||
|
parameters
Basic
|
Navigation method |
QR code/laser SLAM
|
QR code/laser SLAM
|
QR code/laser SLAM | QR code/laser SLAM |
QR code/laser SLAM
|
QR code/laser SLAM | QR code/laser SLAM | QR code/laser SLAM |
| External dimensions(mm) |
1000×800×258
|
796×580×250
|
1330×952×290
|
980×680×245
|
1276×546×365
|
1276×546×365
|
1224×730×420
|
1210×892×280
|
|
| Self weight (including battery)(kg) |
220
|
150
|
265
|
150
|
170
|
320
|
250
|
250
|
|
| Maximum Load |
800
|
300
|
500/1000
|
800
|
600
|
600
|
1000
|
1500
|
|
| Maximum lifting stroke(mm) |
60±1
|
60±2
|
60±1
|
60±2
|
60±2
|
60±1
|
60±1
|
60±1
|
|
| Maximum operating speed(m/s) |
2
|
1.5
|
1.5
|
1.8
|
1.5
|
1.2
|
1.67
|
1.67
|
|
| Linear running acceleration(m/s²) |
Depending on the actual situation
|
Depending on the actual situation
|
Depending on the actual situation
|
Depending on the actual situation |
Depending on the actual situation
|
Depending on the actual situation
|
Depending on the actual situation
|
Depending on the actual situation
|
|
| Navigation position accuracy(mm) |
±5
|
±5 | ±5 |
±5
|
±5 |
±5
|
±5
|
±5
|
|
| Accuracy of lifting and stopping(mm) |
±1
|
±1 | ±1 |
±1
|
±1 |
±1
|
±1
|
±1
|
|
| Minimum passage width(mm) |
860
|
640
|
1050
|
820
|
790
|
660
|
870
|
1000
|
|
| Rotating diameter(mm) |
1100
|
910
|
1460
|
980
|
1015
|
1330
|
1350
|
1415
|
|
| operation temperature(℃) |
-10~45
|
-10~45
|
-10~45
|
-10~45
|
-10~45
|
-10~45
|
-10~45
|
-10~45
|
|
|
Battery
performance
|
Type
|
Ternary lithium
|
Lithium Iron Phosphate
|
Lithium Iron Phosphate
|
Lithium Iron Phosphate |
Lithium Iron Phosphate
|
Lithium Iron Phosphate
|
Lithium Iron Phosphate
|
Lithium Iron Phosphate
|
|
Battery voltage/capacity(V/Ah)
|
48/40
|
48/20
|
48/40
|
48/27
|
48/24
|
48/40
|
48/40
|
48/40
|
|
|
Charging method
|
Automatic charge
|
Automatic charge
|
Automatic charge
|
Automatic charge |
Automatic charge
|
Automatic charge
|
Automatic charge
|
Automatic charge
|
|
|
Comprehensive endurance(h)
|
8 | 8 |
7
|
8
|
8 |
8
|
6
|
6
|
|
|
charging time(10-80%)(h)
|
≤2
|
≤1 |
≤2
|
≤2 | ≤2 | ≤2 |
≤2
|
≤2
|
|
|
safety
protection
|
obstacle detection
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
Detection of collision bars around the fuselage
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
|
EMERGENCY STOP
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
|
Audible and Visual Alarm
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
|
warning sign
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
|
function
|
Roaming function
|
√
|
√ |
√
|
√ | √ | √ |
√
|
√
|
|
Driving method
|
Double wheel diferential
|
Double wheel diferential |
Double wheel diferential
|
Double wheel diferential |
Double wheel diferential
|
Double wheel diferential
|
Double wheel diferential | Double wheel diferential | |
|
Human computer interaction mode
|
Mobile phone/tablet/computer/ remote control/ AGV screen
|
Mobile phone/tablet/computer/ remote control/ AGV screen
|
Mobile phone/tablet/computer/ remote control/ AGV screen
|
Mobile phone/tablet/computer/ remote control/ AGV screen |
Mobile phone/tablet/computer/ remote control/ AGV screen
|
Mobile phone/tablet/computer/ remote control/ AGV screen
|
Mobile phone/tablet/computer/ remote control/ AGV screen | Mobile phone/tablet/computer/ remote control/ AGV screen | |
Hotline